
CooHOI: Learning Collaborative Human-Object Interaction by Controlling Object Dynamics
The official implementation of the paper “CooHOI: Learning Cooperative Human-Object Interaction with Manipulated Object Dynamics”.
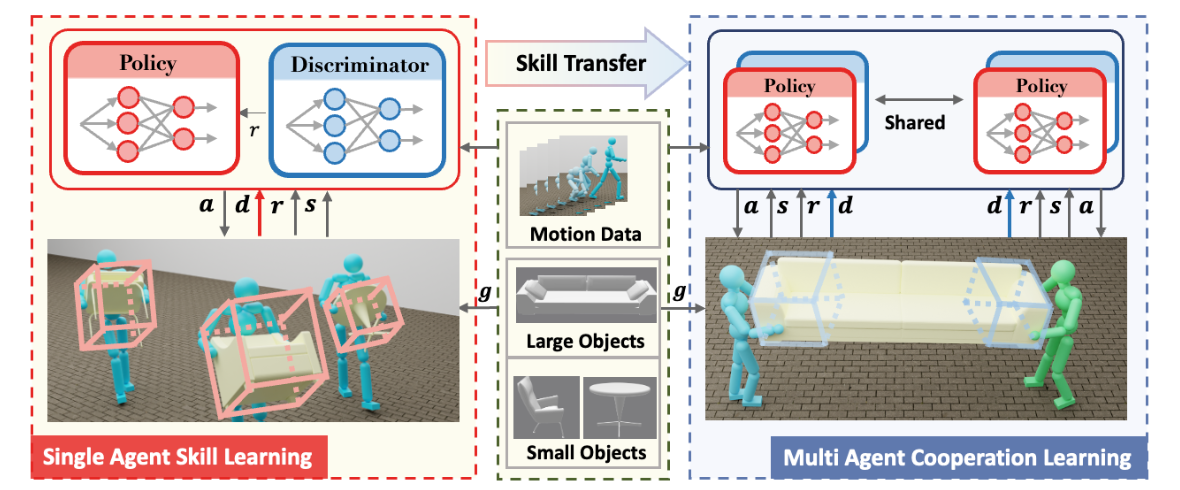
This framework adopts a two-stage learning paradigm. In the first stage, as shown in the left figure, we use the AMP framework to train single-agent handling skills. In the second stage, we transfer these single-agent skills into a collaborative environment. It is worth noting that we utilize the dynamics of objects as feedback information and an implicit communication channel, as indicated by the bounding boxes in the figure.
Installation
Download Isaac Gym (https://developer.nvidia.com/isaac-gym), or use command-line instructions:
Bash
wget https://developer.nvidia.com/isaac-gym-preview-4
tar -xvzf isaac-gym-preview-4
Create a conda environment:
Bash
conda create -n coohoi python=3.8
conda activate coohoi
Install the Python wrapper for IsaacGym:
Bash
pip install -e isaacgym/python
Install other dependencies:
Bash
git clone https://github.com/Winston-Gu/CooHOI
pip install -r requirements.txt
If you encounter the following error: ImportError: libpython3.8m.so.1.0: cannot open shared object file: No such file or directory, you need to set the environment variables:
Bash
export LD_LIBRARY_PATH=/path/to/conda/envs/your_env/lib
View the results for the single-agent object handling task: If memory is insufficient, it is recommended to set num env to 1 or 4.
Bash
CUDA_VISIBLE_DEVICES=0 python coohoi/run.py --test \
--task HumanoidAMPCarryObject \
--num_envs 16 \
--cfg_env coohoi/data/cfg/humanoid_carrybox.yaml \
--cfg_train coohoi/data/cfg/train/amp_humanoid_task.yaml \
--motion_file coohoi/data/motions/coohoi_data/coohoi_data.yaml \
--checkpoint coohoi/data/models/SingleAgent.pth
View our results in the dual-agent object handling task:
Bash
CUDA_VISIBLE_DEVICES=0 python coohoi/run.py --test \
--task ShareHumanoidCarryObject \
--num_envs 16 \
--cfg_env coohoi/data/cfg/share_humanoid_carrybox.yaml \
--cfg_train coohoi/data/cfg/train/share_humanoid_task_coohoi.yaml \
--motion_file coohoi/data/motions/coohoi_data/coohoi_data.yaml \
--checkpoint coohoi/data/models/TwoAgent.pth
Solo Humanoid Robot Skill Training
Training instructions:
Bash
CUDA_VISIBLE_DEVICES=0 python coohoi/run.py \
--task HumanoidAMPCarryObject \
--cfg_env coohoi/data/cfg/humanoid_carrybox.yaml \
--cfg_train coohoi/data/cfg/train/amp_humanoid_task.yaml \
--motion_file coohoi/data/motions/coohoi_data/coohoi_data.yaml \
--headless \
--wandb_name "<experiement_name>"
The model weight files (checkpoints) will be found in the output/Humanoid_<date>_<time>/nn directory for evaluation:
Bash
CUDA_VISIBLE_DEVICES=0 python coohoi/run.py --test \
--task HumanoidAMPCarryObject \
--num_envs 16 \
--cfg_env coohoi/data/cfg/humanoid_carrybox.yaml \
--cfg_train coohoi/data/cfg/train/amp_humanoid_task.yaml \
--motion_file coohoi/data/motions/coohoi_data/coohoi_data.yaml \
--checkpoint <checkpoint_path>
For example:
Bash
CUDA_VISIBLE_DEVICES=0 python coohoi/run.py --test \
--task HumanoidAMPCarryObject \
--num_envs 16 \
--cfg_env coohoi/data/cfg/humanoid_carrybox.yaml \
--cfg_train coohoi/data/cfg/train/amp_humanoid_task.yaml \
--motion_file coohoi/data/motions/coohoi_data/coohoi_data.yaml \
--checkpoint output/Humanoid_19-16-52-17/nn/Humanoid.pth
Dual-Robot Collaboration Training
By default, collaborative training for dual humanoid robots starts with fine-tuning the individual humanoid robot policy. We load the weight file of the single-agent policy in --checkpoint <ckpt_path>, and can replace it with your own weight file.
Collaborative Training:
Bash
CUDA_VISIBLE_DEVICES=0 python coohoi/run.py \
--task ShareHumanoidCarryObject \
--cfg_env coohoi/data/cfg/share_humanoid_carrybox.yaml \
--cfg_train coohoi/data/cfg/train/share_humanoid_task_coohoi.yaml \
--motion_file coohoi/data/motions/coohoi_data/coohoi_data.yaml \
--headless \
--is_finetune \
--pretrain_checkpoint <ckpt_path> \
--wandb \
--wandb_name "<experiement_name>"
Note: <ckpt_path> should be the relative path of the single agent policy weight file. This weight file is used to initialize the collaborative policy.
For example:
Bash
CUDA_VISIBLE_DEVICES=0 python coohoi/run.py \
--task ShareHumanoidCarryObject \
--cfg_env coohoi/data/cfg/share_humanoid_carrybox.yaml \
--cfg_train coohoi/data/cfg/train/share_humanoid_task_coohoi.yaml \
--motion_file coohoi/data/motions/coohoi_data/coohoi_data.yaml \
--headless \
--is_finetune \
--pretrain_checkpoint coohoi/data/models/SingleAgent.pth \
--wandb \
--wandb_name "CooHOI Training"
Evaluation:
Bash
CUDA_VISIBLE_DEVICES=0 python coohoi/run.py --test \
--task ShareHumanoidCarryObject \
--num_envs 16 \
--cfg_env coohoi/data/cfg/share_humanoid_carrybox.yaml \
--cfg_train coohoi/data/cfg/train/share_humanoid_task_coohoi.yaml \
--motion_file coohoi/data/motions/coohoi_data/coohoi_data.yaml \
--checkpoint <ckpt_path>
Other reference content
- The initial code is based on ASE project .
- The motion dataset comes from AMASS dataset .
- The object dataset comes from SAMP dataset .